Aakarsh Sangar

Projects

ModalAI Internship

High school engineering internship · 2024–2025

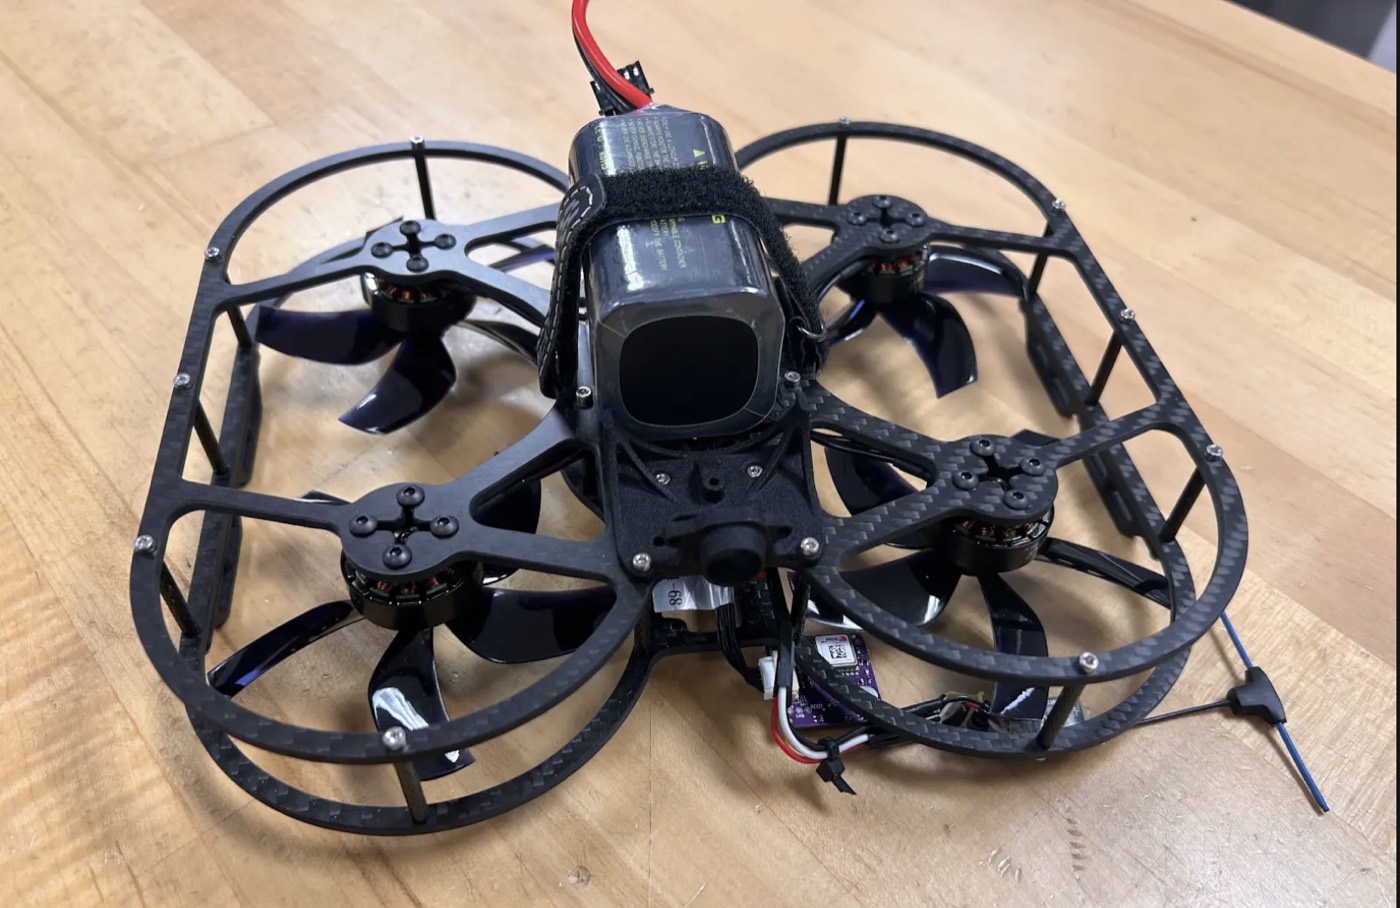
I helped bring a VOXL 2 Mini-based drone from assembly through embedded-camera calibration and physical flight testing. The work required separating hardware, communication, software, and flight issues into testable stages.

  • Assembled hardware, repaired GPS wiring, and tested RC and QGroundControl behavior.
  • Integrated the tracking camera, verified its VOXL connection, and completed fisheye calibration.
  • Helped convert the bring-up process into a repeatable assembly and setup manual.
View iteration cycle
VOXL 2 Mini-based drone used during Aakarsh Sangar's ModalAI internship
Integrated drone platform used for camera and flight testing.

Custom Robotic Arm

Personal project · 2025–present

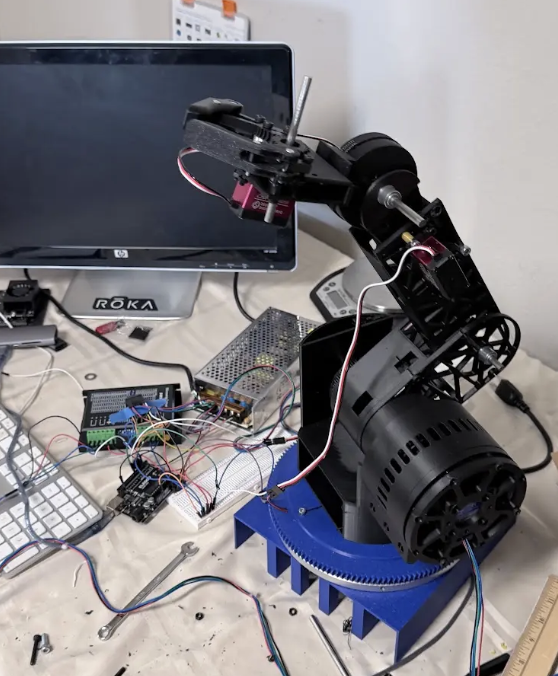
I am developing a multi-joint arm as a practical platform for mechanism design, actuation, electronics, and control. I designed the system architecture, trussed links, rotating base, gripper, drivetrain packaging, and most custom parts in CAD before printing and assembling the mechanism.

  • Integrated a 24 V stepper power stage using DM542 and TMC2209 drivers.
  • Replaced a packaging-limited shoulder belt reduction with a custom 8:1 planetary actuator design.
  • Current work: joint calibration, repeatable motion, and camera-based block detection.
View iteration cycle
Current physical prototype of Aakarsh Sangar's robotic arm
Current physical prototype during electronics integration.

FTC Robotics

Team 18263 High Voltage · 2020–2026

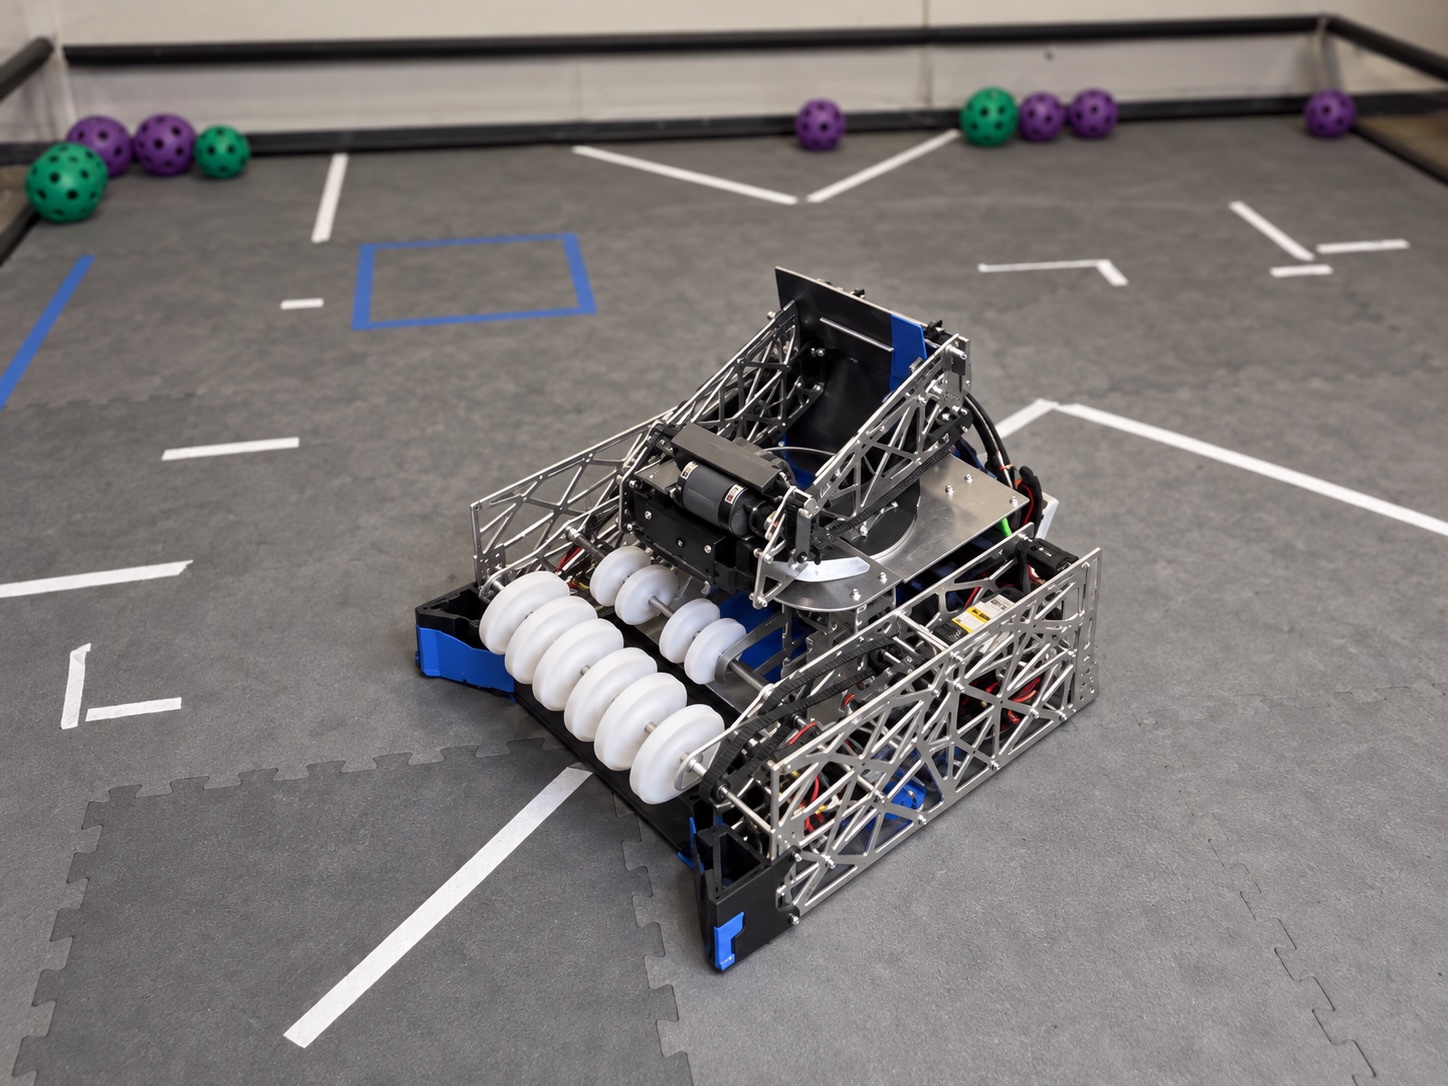
As a CAD lead and builder, I modeled most of the custom robot and used the full assembly to coordinate the intake, transfer, turret, shooter, sensing, and frame within a compact competition envelope. I carried those decisions into fabrication, assembly, and testing.

  • Designed subsystem interfaces, custom plates, and mechanism geometry in Onshape.
  • Resolved ball-path alignment, service access, interference, and mounting constraints in system-level CAD.
  • Contributed to selected AprilTag, turret-aiming, PID, and sensor-triggered control work.
View iteration cycle
FTC competition robot undergoing integrated testing on the field
Integrated robot during field validation.

Software Projects

Faultline

A hackathon prototype for gathering research sources, comparing conflicting evidence, and preserving the workflow behind its output.

rPPG Pipeline

A Jetson Orin Nano experiment that processes subtle color changes in camera video into a pulse-related signal.